Hardware LabSoftware LabClient project
Autonomous Tea-Leaf Plucking Robot
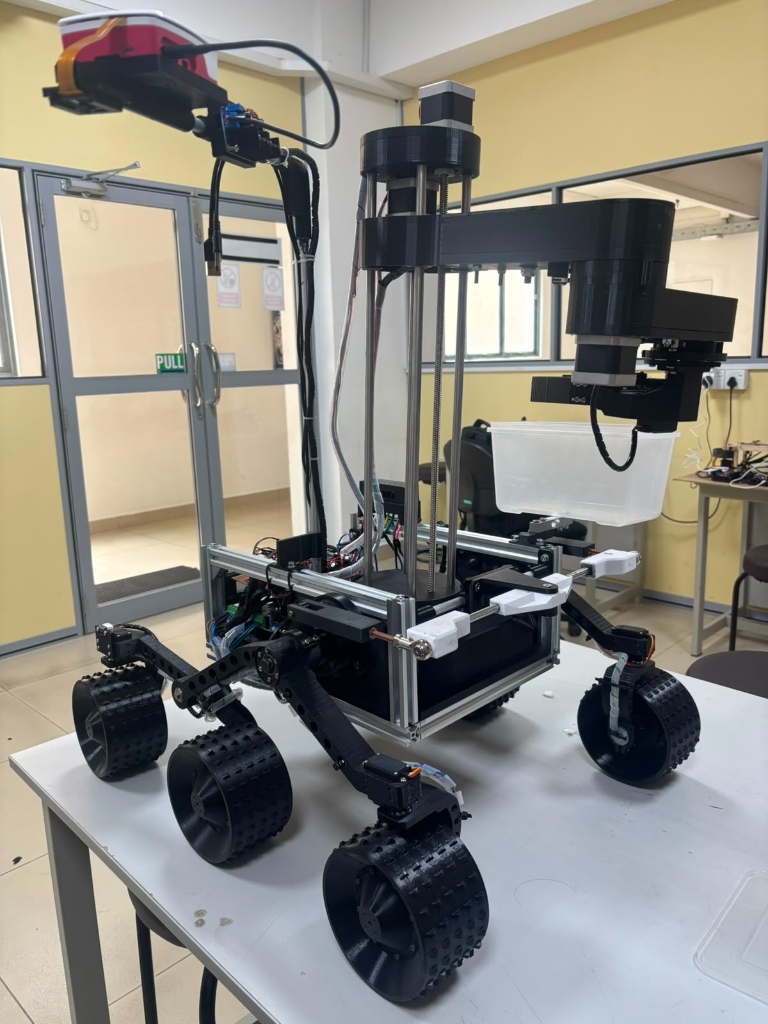
An agricultural robotics rover combining rough-terrain mobility, stereoscopic computer vision, and an automated harvesting arm for tea cultivation.
- bud detection accuracy
- 94%
- pluck cycle duration
- 1.4s
The challenge
Identifying optimal two-leaves-and-a-bud flushes and automating the delicate picking process in high-altitude agricultural environments.
What we built
A mobile rover integrating a rocker-bogie terrain chassis, multi-axis robotic harvesting arm, and computer vision powered by a Raspberry Pi 5 and ESP32.
Tools
- Robotics
- Raspberry Pi 5
- ESP32
- Computer Vision
- Embedded Systems
- AI
The result
Demonstrated automated tea bud recognition and selective harvesting with integrated mechanical design and real-time edge image processing.